Choose the Task Before the Robot
The most common mistake in robot projects is buying a machine before defining the job. Start by identifying tasks that are repetitive, physically demanding, hazardous or difficult to staff consistently. Loading and unloading, machine tending, palletising, deburring, dispensing and inspection are reliable starting points because the motion is predictable and the quality benefit is measurable.
Payload Is More Than Part Weight
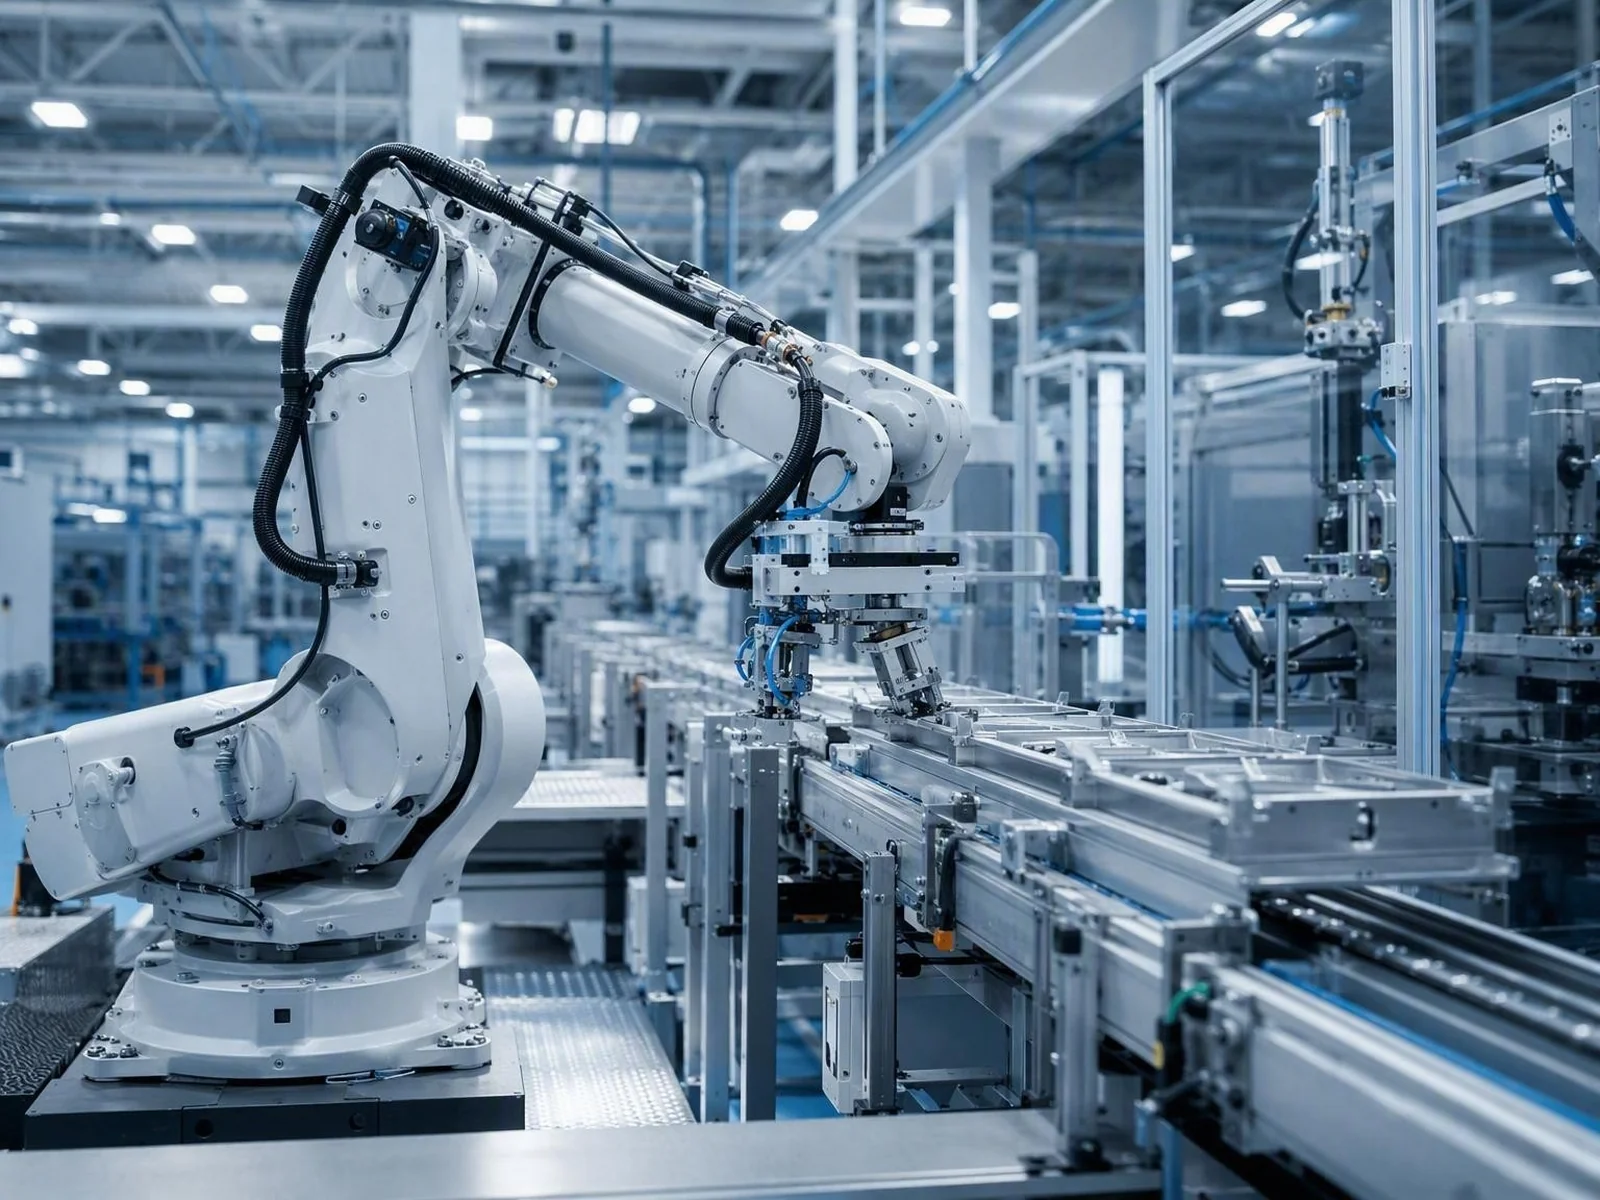
Robot payload ratings include the end-of-arm tooling, not just the workpiece. A gripper, vacuum cup assembly or welding torch can weigh several kilograms, and its centre of gravity sits far from the mounting flange. This offset reduces the effective payload and can force a larger robot class than the part alone would suggest. Calculate total moving mass and its moment before sizing the arm.
Reach, Cycle Time and Layout
Required reach is determined by the working envelope, not by a single pick point. Map every position the arm must touch, then allow margin for safe clearance and future changes. Cycle time should be derived from the line takt: a robot that is fast enough on paper but cannot keep pace across a full cycle creates a bottleneck rather than relieving one.
End-of-Arm Tooling Decides Success
Tooling is where most integration risk sits. Grippers must match part geometry, surface finish and tolerance variation; vacuum systems must suit porosity and surface condition; and quick-change interfaces pay back quickly where a cell handles several part variants. Tooling design deserves as much engineering attention as robot selection.
Safety and Compliance
Assess risk before installation. Depending on the application, protection may rely on physical guarding, interlocked light curtains, safety-rated scanners or a certified collaborative configuration with force and speed limits. The assessment must cover the full cell including pinch points, ejected parts and maintenance access, and it should be documented for audit.
Integrating with Existing Controls
A robot cell must coexist with what is already on the floor. Plan the interface to the PLC: handshake signals for part present, cycle complete and fault, plus interlocks that stop both sides safely. Where the existing machine communicates over a fieldbus, matching that protocol keeps commissioning short and gives operators a single view of the process.
Plan for Change
Production requirements shift. Leaving spare inputs and outputs, reserving floor space for an additional fixture, and keeping tooling modular make later expansion straightforward instead of forcing a rebuild.